Control and Guidance of Surface Vessel
The goal of this project is to implement a line-of-sight-based guidance system and an integrated PID controller.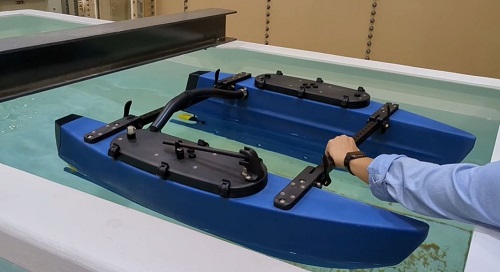
The goal of this project is to implement a line-of-sight-based guidance system and an integrated PID controller.
Image dehazing models based on generative artificial intelligence, specifically focusing on diffusion models.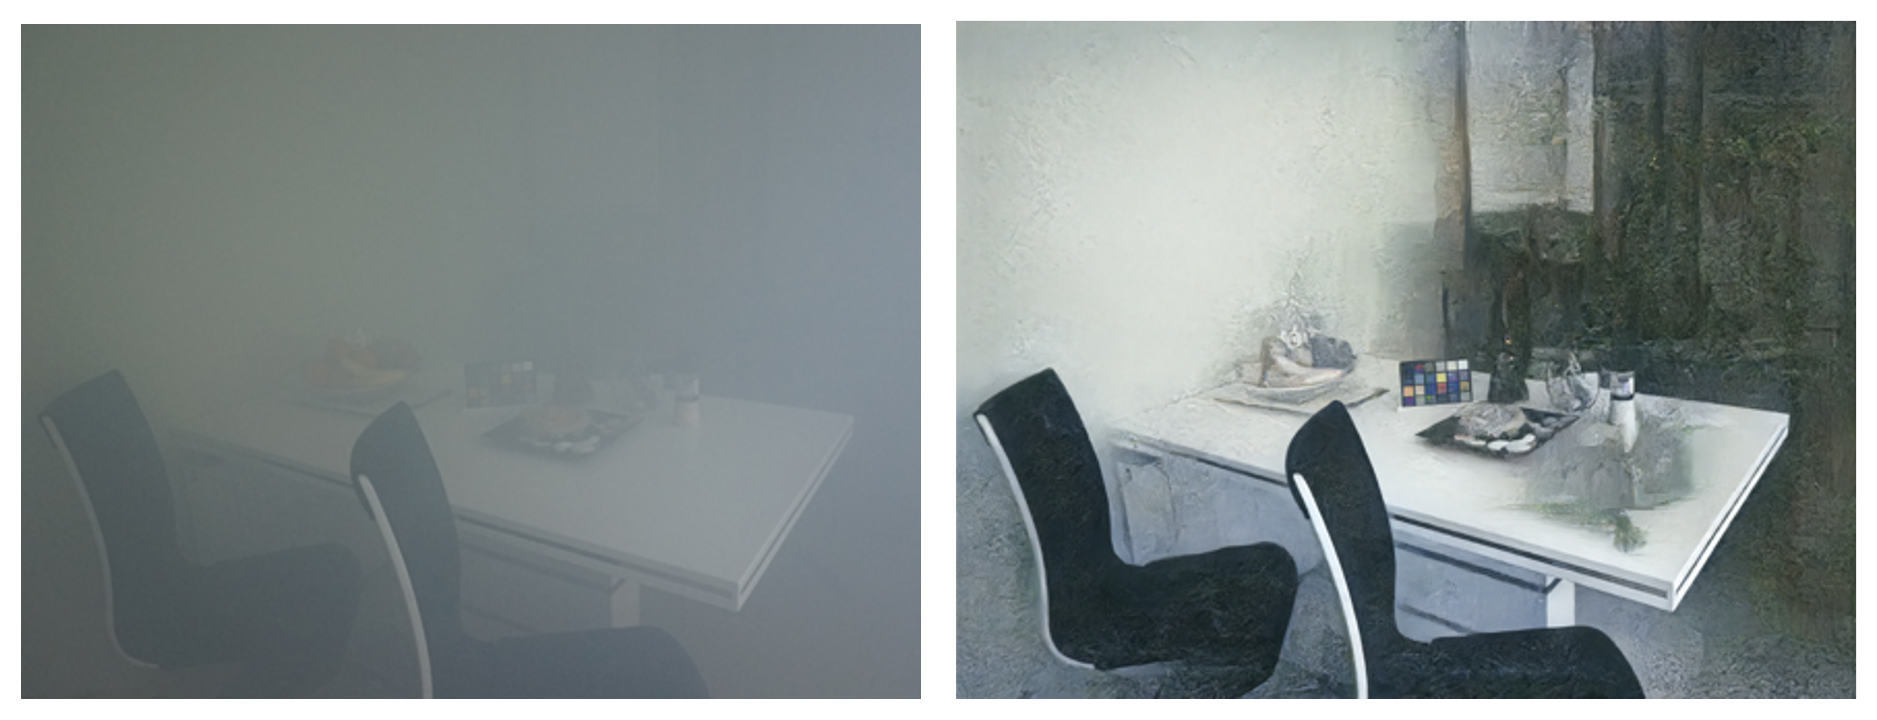
We explored vision-language segmentation models (VLSMs) for medical imaging, focusing on the interplay between text and image features..JPG)
Published in IEEE International Conference on Control, Automation and Systems (ICCAS), 2023
This paper discusses the development of an on-the-move satellite communication algorithm for maintaining connectivity between LEO satellites and moving vehicles on the ground.
Recommended citation: S. Huang, P. Chang, X. Lu, and J. Juang. (2023). "A Satcom On-the-Move Phased-Array Antenna Tracking Algorithm on Robot Operating System." IEEE International Conference on Control, Automation and Systems (ICCAS).
Download Paper
Published in IEEE International Conference on Machine Learning and Applications (ICMLA), 2024
This paper discusses the deployment of machine learning (ML)-based object detection and segmentation models on edge platforms to enable real-time caveline detection for Autonomous Underwater Vehicles (AUVs) used in underwater cave exploration and mapping.
Recommended citation: M. Mohammadi, S. Huang, T. Barua, I. Rekleitis, M. J. Islam, and R. Zand. (2023). "Caveline Detection at the Edge for Autonomous Underwater Cave Exploration and Mapping." IEEE International Conference on Machine Learning and Applications (ICMLA).
Download Paper
Published in Robots for Understanding Natural Ecosystems (RUNE) Workshop at IEEE International Conference on Robotics and Automation (ICRA), 2024
This paper discusses the design, development, and early field experimental analysis of a portable, scalable, and low-power solution for multimodal light-field sensing in vulnerable coastal communities in Florida, US.
Recommended citation: S. Huang, A. Abdullah, R. Chen, and M. J. Islam. (2024). "Dynamic Light-field Sensing for Distributed Light Pollution Monitoring." Robots for Understanding Natural Ecosystems (RUNE) Workshop at IEEE International Conference on Robotics and Automation (ICRA).
Download Paper | Download Slides
Published in arXiv and now under review at the IEEE Journal of Selected Topics in Applied Earth Observations and Remote Sensing (JSTARS), 2024
This paper is about an interactive interface designed to survey, simulate, and visualize light-fields and light pollution maps in real-time.
Recommended citation: S. Huang, K.F.F. Suhi, and M. J. Islam. (2024). "LightViz: Autonomous Light-field Surveying and Mapping for Distributed Light Pollution Monitoring." Under review at the IEEE Journal of Selected Topics in Applied Earth Observations and Remote Sensing (JSTARS).
Download Paper
Undergraduate course, National Taiwan Ocean University, Department of Electrical Engineering, 2018
Lecture: Engineering Mathematics
Graduate course, National Chiao Tung Univeristy, College of Electrical and Computer Engineering, 2021
Course: Linear System Theory, Control Lab., Principle of Microcomputer.